
Fundstrat research has long highlighted the demographically driven labor shortage that has already begun to arise and is projected to intensify over the next few decades. We have long discussed how this acts as a driver for the development and advancement of AI and automation.
Those trends are already beginning to manifest, with observers anticipating that AI will make many human jobs unnecessary, either by eliminating the roles altogether or by reducing the number of humans needed to fill them. Among the jobs impacted are bookkeepers, coders, and paralegals, not to mention low-level customer-service reps and copywriters. It’s hard to miss the fact that the affected jobs have mostly been so-called “white-collar” jobs.
To be sure, automation has long affected those jobs that primarily involve physical labor. As we wrote about back in 2023, the first industrial robot was deployed back in 1961, and robots have been significantly reducing the need for human physical labor since the 1980s. But recent advances in AI have not significantly accelerated that trend.
There’s a reason for that.
When it comes to training AI, simulating human thought is actually the low-hanging fruit. There’s so much training data available – think of all the text that’s been written throughout human history, much of it already digitized. The same has not been the case with data that can be used to train humanoid machines on how to move. After all, motion pictures weren’t invented until the late 1800s. What’s more, it did not become feasible to generate mass quantities of video suitable for training AI until the late 2000s, with the rise of mobile devices and later, HD video capture capabilities. The ability to simulate environments with sufficient realism, detail, and scale for an alternate method of physical AI training did not come into existence until just a few years ago.
We will return to the topic of training a physical AI in the next installment of Signal From Noise. However, the difficulties in training a physical AI model are just part of the challenge. For physical AI, we don’t just need an artificial intelligence. We need an artificial body as well, and it has taken quite a while for engineers to achieve anything that can come close to simulating human movement.
Feats that most humans accomplish without thinking every day can actually be remarkably challenging. Back in 1996, it was big news when Honda publicly unveiled the first-ever self-contained humanoid robot that could walk. Walking is an amazingly difficult and complex task – so much so that animators have always been challenged to depict characters walking in a realistic fashion. (As a side note, one reason for the hype around the pending release of Grand Theft Auto VI, the latest in the iconic video-game franchise, is the vastly improved realism in its animation quality, particularly the way game characters walk).
If you think about it, walking is actually difficult for adults as well: When humans are immobilized for extended periods of time by injury or illness, they often need to be taught how to walk again by physical therapists, and that’s not just because of muscular atrophy. The neuromuscular pathways that enable most of us to walk without much conscious thought erode with disuse, and the renewed need to coordinate everything consciously becomes draining and frustrating until those pathways are restored.
That’s why ever since the first industrial robot was deployed back in 1961, most robots have remained limited to mostly menial tasks that can be very specifically performed under very controlled conditions, such as one- or two-step assembly-line work. They are usually bolted to a spot on the factory floor, and they are generally tasked only with performing predetermined sequences of movements while manipulating a finite number of uniform objects.
Yet this seems about to change. The latest robots wowing audiences – think of the kung-fu robots that China’s Unitree showcased earlier this year – did not display true physical AI: they were not fully spontaneous in their autonomy. Yet even though they were “only” performing a pre-choreographed routine (much as human kung-fu practitioners often do as part of their training) that had been exhaustively “rehearsed” and calibrated by humans, these latest robots displayed an impressive level of movement quality. Before androids of this level of sophistication were engineered, there arguably wasn’t much point to developing physical AI.
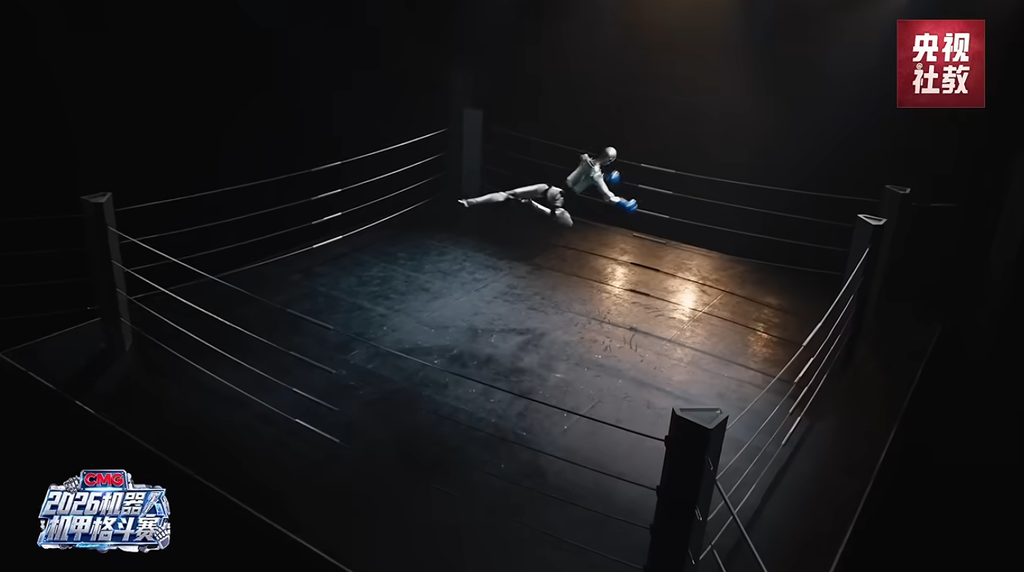
Thus, in this installment of Signal From Noise, we will begin our discussion about physical AI by first describing the mechanical engineering required to make developing a physical AI possible.
What’s the difference between robots and physical AI?
In a nutshell, it’s comparable to the difference between conventional software and the kind of AI on offer from the likes of OpenAI, Google, and Anthropic (as well as DeepSeek, Moonshot, and Mistral). Software is a bundle of very complex instructions, complete with algorithms that help the software “decide” how to respond to a very finite set of variables. However, it is limited: it can only do what the software development team explicitly conceived of. While this actually covers quite a range of complex tasks, it nevertheless represents a hard limit.
An AI, however, is capable of performing tasks that the coders and developers did not explicitly conceive of having it do, whether it is fine-tuning your personal, top-secret fried-chicken recipe (that’s an actual task that AI successfully performed for me this summer) or identifying the proteins causing a disease and discovering drug candidates that could help counter them. An AI can also become more capable: it can learn, or train, in a field of specialized knowledge and then personify an expert in that field, answering questions or generating a knowledgeable, domain-specific analysis.
Perhaps the most commonly encountered form of physical AI right now is a self-driving automobile. Software can control a self-driving car on a closed course, but it takes physical AI to create a car that can drive autonomously on the uncontrolled conditions of an open road.
That’s the case with many other seemingly simple tasks. A robot can be programmed to fold a series of essentially identical, freshly made shirts coming off an assembly line. Physical AI is needed if we want a robot to fold our household laundry.
The goal with physical AI is to help machines (including but not limited to robots) carry out physical tasks in a largely uncontrolled environment with minimal instruction. In fact, the aim with physical AI is arguably to create machines that can learn how to perform physical tasks and actions with little to no intervention by a programmer.
We should not underestimate the speed at which AI is advancing, but neither should we underestimate the challenge involved. Those kung-fu robots I mentioned earlier might look impressive (full disclosure: I was impressed). However, even they have yet to prove themselves as factory robots, frequently falling short on speed and error-free performance.
For the physical aspect of Physical AI, we rely on advances in three key areas.
Vision, AI style
Navigating the physical world depends on effective, efficient, real-time sensory input that transcends mere image recognition. While current AI-powered image recognition plays a role, a machine needs more in order to successfully move through an often-chaotic physical environment, where shifting light and physical obstacles require interpolation and data in three dimensions.
The sensors involved include video cameras, along with radar, LiDAR, and structured light systems that are used to enhance three-dimensional visual data, including data about objects in motion. [Note: a structured-light system provides 3D information by projecting a specific light pattern at an object and measuring how that object distorts its shape.]
Publicly traded companies that develop and manufacture such equipment include:
- Sony SONY 1.40% . The electronics giant is integrating AI-powered silicon directly onto its sensors, combining vision with the “brains” needed to understand what is being seen without the need to transmit raw video to a server for processing. The company is also developing motion-based computer vision that mimics how human retinas respond more readily to only what changes (i.e., what moves) from one fraction of a second to the next, cutting back on processing resources required. Sony’s CMOS and time-of-flight modules are being geared for industrial, personal, and automotive applications.
- Ouster OUST 8.74% . Ouster is a manufacturer of LiDAR solutions. LiDAR refers to bouncing lasers off of objects, measuring how much time it takes for each beam to bounce back to provide information about an object’s 3D shape and location. (It’s similar in concept to radar). Where Ouster differs from the many other LiDAR companies out there is its all-digital approach, rather than an analog approach that relies more heavily on tiny spinning mirrors and other mechanical components. Ouster’s hi-definition approach is not only more durable, but streamlines the processing of the visual data (no need to convert from analog to digital). The company is also researching how to apply AI to process the data in real time, so that its product identifies what it “sees,” can track the object as it moves, and predict where it will be in the immediate future.
- Teledyne Technologies TDY 0.73% . A primary challenge for vision, both human and machine, is what happens when light isn’t enough. Maybe it’s dark, or maybe it’s foggy, rainy, or smoky. Teledyne is developing vision that pairs infrared (i.e., heat-sensitive) with visible-light solutions. Such solutions are already part of military applications such as attack drones, but they have implications for physical AI in developing robots that can work in hazardous conditions.
Internal perception
It is not enough to see well, of course. A different set of sensors is used to help a machine move itself. Humans (and many other animal species) have unique sensors that combine to give us what is known as proprioception. This is how a human can keep track of the position of every physical part of their body as it moves through space without consciously looking at it. One of the more important attributes that separates a great athlete from an everyday person like me is a high level of proprioception.
Proprioception enables a great gymnast like Simone Biles to navigate flips, twists, and turns as she soars through the air after a vault. It’s what enables a great soccer player like Lionel Messi to dribble through a horde of defenders without looking at the ball at his feet. It’s also how a great pianist like Yuja Wang can thunder through Rachmaninoff’s Third Concerto without looking at the keys. For the rest of us mere mortals, proprioception is how we are able to button our shirts, bring forkfuls of pie to our mouths, or walk down a cobblestone street without looking.
If a physical AI is going to be useful (or if it’s just going to perform the complex flips, leaps, and high-flying kicks that form part of a choreographed kung-fu routine), it needs its own artificial proprioception. This includes sensors to measure a machine’s own movement through space – inertial measurement units (IMU) to track acceleration and orientation, ultrasonic transducers (a sort of sonar used for close-range proximity detection), and tactile and force-torque sensors to provide feedback as a machine grasps and manipulates other objects.
Wait, there’s more. The human nervous system is designed so that your hand automatically flinches back when accidentally touching a hot stove, because the lag time it would take for a heat signal to reach your brain and for your brain to process the information and tell you to pull back could be too slow to prevent catastrophic injury. The machine sensors we’re talking about need to be bundled with processors to speed response time for a comparable reason. They also need to be tiny, light, and low-powered. And, no pressure here, but they also need to be rugged enough to withstand shocks, moisture, dust/dirt, and other environmental hazards.
Publicly traded companies that develop and manufacture such components include:
- STMicroelectronics (STM 7.03% ). STM is a leading developer of accelerometers, gyroscopes, and multi-axis IMUs. STMicroelectronics integrates AI-powered processors into its sensors to reduce response time for motion sensors and motion-control chips. Their size and experience have resulted in what the company believes to be superior economies of scale.
- Analog Devices (ADI 3.09% ). Analog Devices has long been a leading producer of mixed-signal processors, which convert analog real-world information into digital data that processors can use. For physical AI, it is also a producer of high-precision IMUs that can track movement, orientation, and position – with minimal need for maintenance. The company also offers precise angle and force sensors suitable for the high levels of dexterity required by robot hands – so that the same robot hand can hold an egg without crushing it but also pour a mug of coffee from a heavy pitcher. Integrated into its products are self-contained diagnostics that can predict when its sensors will soon need adjustment, repair, or replacement, and algorithms to verify data in real time before it is sent to a processor.
- TE Connectivity TEL 1.19% . TE Connectivity produces some of the same devices as the previous companies – force-torque sensors, position sensors, and ultrasonic sensors, for instance. Where TE Connectivity strives to differentiate itself is in durability, focusing on products that can survive often-abusive real-world conditions: heat, cold, wear and tear, vibration, shock, etc. The company doesn’t just focus on the sensors in this regard, but on the connections and mountings that attach the sensors to the machines in question.
- Murata Manufacturing MRAAY. This Japanese company makes motion sensors, ultrasonic transducers, and vibration sensors. The company’s differentiators include a focus on sensors that provide tactile feedback, better enabling dexterity and coordination. The company is also noted for its expertise in incorporating specialized ceramics into its designs, facilitating miniaturization, stability, and durability – as well as the ability to stack multiple sensors into a single component.
Because physical AI-empowered machines will likely include multiple sensors across numerous modalities, the interpretation of such data will be key – and it’s not just a software problem. What will be needed is small, low-power, high-speed, deterministic signal-transmission hardware, synchronization precision beyond the millisecond level, and platforms capable of integrating all of that information into a reliably continuous feedback loop.
To put that jargon in a more easily understood context, imagine trying to place a glass of water on a table. If the communication between your brain, your eyes, and the muscles controlling your arm/hands were to get out of sync by even a fraction of a second, you might end up releasing the glass too early, dropping it on the floor – or worse, slam the glass down too hard, driving shards of glass into your hand. (This is basically what afflicts those suffering from dysmetria, sensory ataxia, or other neurological conditions.)
To improve response time, reduce latencies, and ensure data cleanliness, specialized hardware deployed within the various sensors will be needed to act as a middle man before information even reaches the AI. The hardware necessary will include in-sensor processing units, Field-Programmable Gate Arrays (FPGAs), neural processing units (NPUs), and low-power digital signal processors (DSPs).
Publicly traded companies developing such solutions include
- AMD AMD 2.93% . AMD’s offerings in this regard include high-speed sensor bridging and adaptive-logic FPGAs and Adaptive Systems-on-Chips (SOCs) that can be easily modified for changing sensor protocols. In other words, AMD’s chips can be easily configured to work with different cameras and sensors.
- Ambarella AMBA -2.35% . Ambarella offers System-on-Chip (SOCs) that can process large volumes of high-resolution visual, radar, or sensor data at speed, using very little power.
- Lattice Semiconductor LSCC 4.27% . If Ambarella focuses on on-site micro-processing of sensor data, Lattice focuses on doing the same for joints, limbs, and other types of motive hardware. Lattice claims its hardware is capable of deterministic control-loops executing in 500 nanoseconds or less (which incidentally is significantly faster than human reflexes.)
- Microchip Technology MCHP 3.40% . Speed and low power consumption are also key to converting analog physical signals into digital data packets in a manner conducive to physical AI. Microchip’s DSPs act as the middleman between sensors and a central AI.
- NXP Semiconductors NXPI 1.87% . NXP’s focus (in this context) is on chips that control the electric motors and hardware that carry out motion, ensuring that the movements are sufficiently smooth and precise.
Motion
Thus far, our discussion of physical AI has dealt with attempts to create an analog to the human nervous system, except for the brain. Before we move onto the actual AI, however, we also need to discuss replicating the skeletomuscular system as it would apply to intelligent humanoid robots. That is to say, how would a humanoid robot (whether AI-empowered or not) actually move?
In the place of contracting muscle fibers, tendons, and ligaments, machines use specialized gears, motors, and other mechanical devices to move limbs and other devices. The actual motion would be driven by frameless, brushless DC motors. Such motors feature better durability and faster response times, they operate quietly, and they feature a high strength-to-weight ratio. Major manufacturers include Regal Rexnord RRX 2.11% , Novanta NOVT 3.70% (through its Celera Motion subsidiary), Moog Inc. MOG-A, and Ametek AME 1.14% .
If such motors generate the “muscular” power, then the tendons, ligaments, and joints are represented by:
- Linear actuators: Used to transfer and direct force, translating the rotational power generated by a motor into largely linear (push-pull) motions. Linear actuators can be useful in robotic analogs for knees and ankles.
- Planetary Actuators: Enable shock absorption in joints that are expected to both absorb impact and make dynamic force adjustments (for instance, for balance). Planetary actuators are another option for joints like hips, knees, and ankles.
- Cycloidal drives: Add stability to rotary joints that are required to absorb extreme shock, for instance in parts mimicking the functionality of pelvises and hips.
- Cable/tendon drives: Placing motors in small joints like fingers can present engineering challenges, so cable/tendon drives enable the motors to be placed elsewhere and transfer the power through what is essentially braided metal and synthetic cable.
- Harmonic drive reduction gears: Used to multiply torque (rotational force) in shoulder-like joints, as well as hinge joints such as elbows.
When it comes to manufacturers of such components, Japanese companies are disproportionately well represented. They include companies like THK THKLY, Harmonic Drive Systems HSYDF, and Nabtesco NCTKY. U.S. publicly traded companies in this space include Moog Inc., Regal Rexnord and Ametek.
Conclusion
We have just completed a discussion about the engineering technology that goes into building a humanoid robot that can perform physical, non-menial work in the real world. Though most of the companies we discussed are not intensively focused on the development of artificial intelligence, their products and technologies will increasingly incorporate and facilitate the development of physical AI, which is the next frontier in this AI revolution. One could argue that consumers would rather have AI doing the menial tasks like laundry and cleaning rather than their jobs, so the advancements in physical AI become all the more important to watch.
In the next Signal From Noise, we will discuss training physical AI itself.
As always, Signal From Noise should not be used as a source of investment recommendations but rather ideas for further investigation. We encourage you to explore our full Signal From Noise library, which includes a look at cybersecurity stocks, companies making “moonshot” bets, the investment trends driven by Gen Xers, and the recent memory chip gold rush. You can also find our take on the future of malls, drone warfare, space-exploration investments, and more.